Systems, Backend and Robotics in Miami, FL, USA

Franco Silvestri

I build real-time, distributed, and backend systems, from perception on quadruped robots to enterprise platforms at scale.

scroll
GPA 3.95 / 4.0 DEGREE BS 2027, MS 2028 (4+1) FOCUS Distributed & Real-Time Systems LANGS Python, C++, Java, JS/TS
22×
Inference latency
reduction
2,900
Automated tests
on the SaaS
110+
Enterprise systems
on CI/CD
16+
Robotics workshops
led & taught
00

About

Hi, I'm Franco. I like problems where correctness, performance, and scale all matter at once: running two deep models on a single embedded GPU in real time, keeping 110+ enterprise services shipping through hardened pipelines, or designing an authorization layer that no endpoint can bypass.

I work across the stack, from C++ on robots to Python backends to Kubernetes in production, and I care about systems that hold up after the demo is over. Most days you'll find me in the Applied Research Center lab, teaching a quadruped to understand the world a little better.

01

Experience

FIU Applied Research Center
Jan 2024 - PresentMiami, FL, USA

Robotics Research Assistant, Perception & Systems Lead

DOE MSIPP, with Savannah River National Lab & Oak Ridge Y-12
  • Cut real-time inference latency 22× over an unoptimized PyTorch GPU baseline (CUDA, quantization, TensorRT) for a DeepLabV3+/STEGO segmentation pipeline that achieved a maximum of 72% mIoU across 21 navigation-critical classes, deployed onboard for real-time field demonstrations alongside a Gaussian Process model on one Jetson Orin Nano.
  • Designed a sensor-agnostic ROS 2 node architecture so new sensors integrate without touching downstream navigation, mapping, or visualization, then deployed across multiple robotic platforms.
  • Built distributed ROS 2 components in C++/Python and designed the robot's networking infrastructure from scratch (IP addressing, low-level Linux, DDS tuning, traffic prioritization), owning bottleneck analysis across the sensor-to-inference-to-operator path to hold real-time latency under load.
  • Built an online Gaussian Process node in GPyTorch (CUDA), fine-tuned to the live CO2 sensor response; exposes feed and predict ROS 2 services that return mean and uncertainty for adaptive sampling, running concurrently with the segmentation model on the Jetson.
  • Fused Velodyne lidar with six depth cameras into a unified point cloud; implemented SLAM with Nav2 planning and open-frontier exploration of unknown environments.
Genworth Financial
Summers 2025 & 2026Richmond, VA, USA

IT Development Program, Returning Intern

Two rotations across two summers
May 2026 - Aug 2026
Platform Engineering & DevOps, Architecture Team
  • Standardized CI/CD across a 110+ system enterprise portfolio, building end-to-end pipelines for 80+ applications via reusable GitLab CI templates per app type (React/Angular, Node, Java REST, monoliths).
  • Raised the portfolio's average internal DevOps Adoption score from 39 to 75, the highest company-wide score among teams with comparably large portfolios.
  • Integrated SAST, DAST, and dependency scanning into every pipeline; reverse-engineered each application's codebase, authentication structure (permissions, tokens, protected routes), and dependencies to configure custom scans that run against secured endpoints across many different system types.
  • Automated artifact promotion and deployment to the servers with Jenkins; containerized workloads with Docker and tuned Kubernetes resource allocation per system.
Summer 2025
Application Development, IT Sourcing & Supply Management
  • Owned an enterprise supplier-feedback product end-to-end on Microsoft Power Platform, replacing manual Outlook tracking and 100+ per-supplier Excel workbooks for a 50+ person department, cutting feedback collection from hours to minutes.
02

Projects

Co-founder and Sole Backend Engineer

Formira Pharmacy quoting and compliance SaaS

Feb 2023 - Present

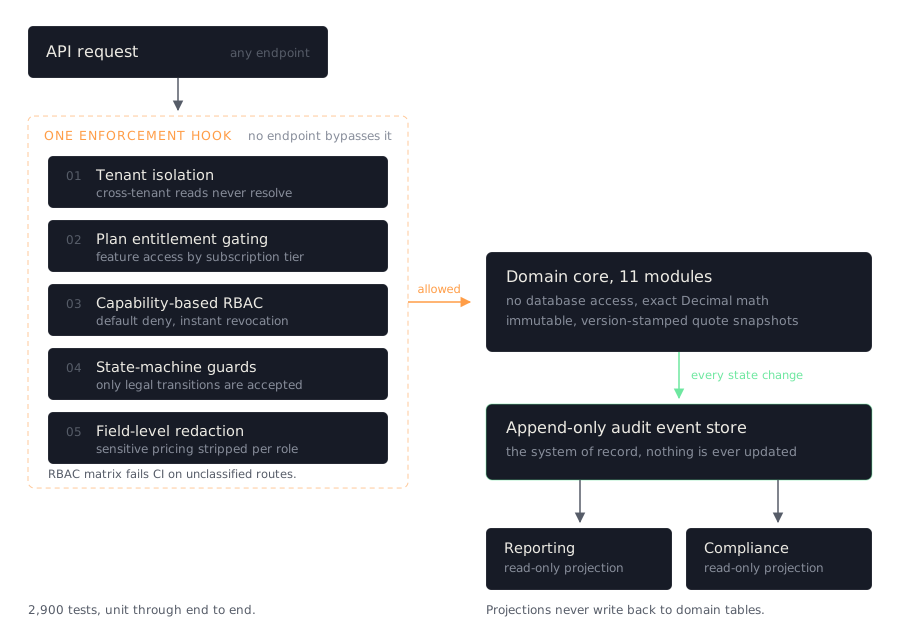
Own the entire backend of a multi-tenant SaaS pharmacies use to price compounded formulas and stay auditable. 11 domain modules around a core that touches no database, so financial math is exact Decimal and every quote is an immutable, version-stamped snapshot. Preparing pilot launch.

5authz layers, one hook
11domain modules
2,900automated tests
0endpoints that can bypass
PythonDjango RESTPostgreSQLDockerCI/CD
Formira request path. An API request passes through five authorization layers, tenant isolation, plan entitlement gating, capability-based RBAC, state-machine guards and field-level redaction, all inside one enforcement hook, before reaching a domain core of 11 modules. Writes emit events into an append-only audit store, and reporting and compliance are read-only projections over it.
The request path. Every call crosses the same five gates before it reaches domain logic, so a new endpoint cannot ship without authorization. Writes land in the audit store first, and reporting and compliance only ever read from it. click to enlarge, or swipe it on a phone
Detection Model and Inference Service, Team of 3

ASL Arcade Real-time American Sign Language recognition

36 hours at ShellHacks 2024, Florida's largest hackathon

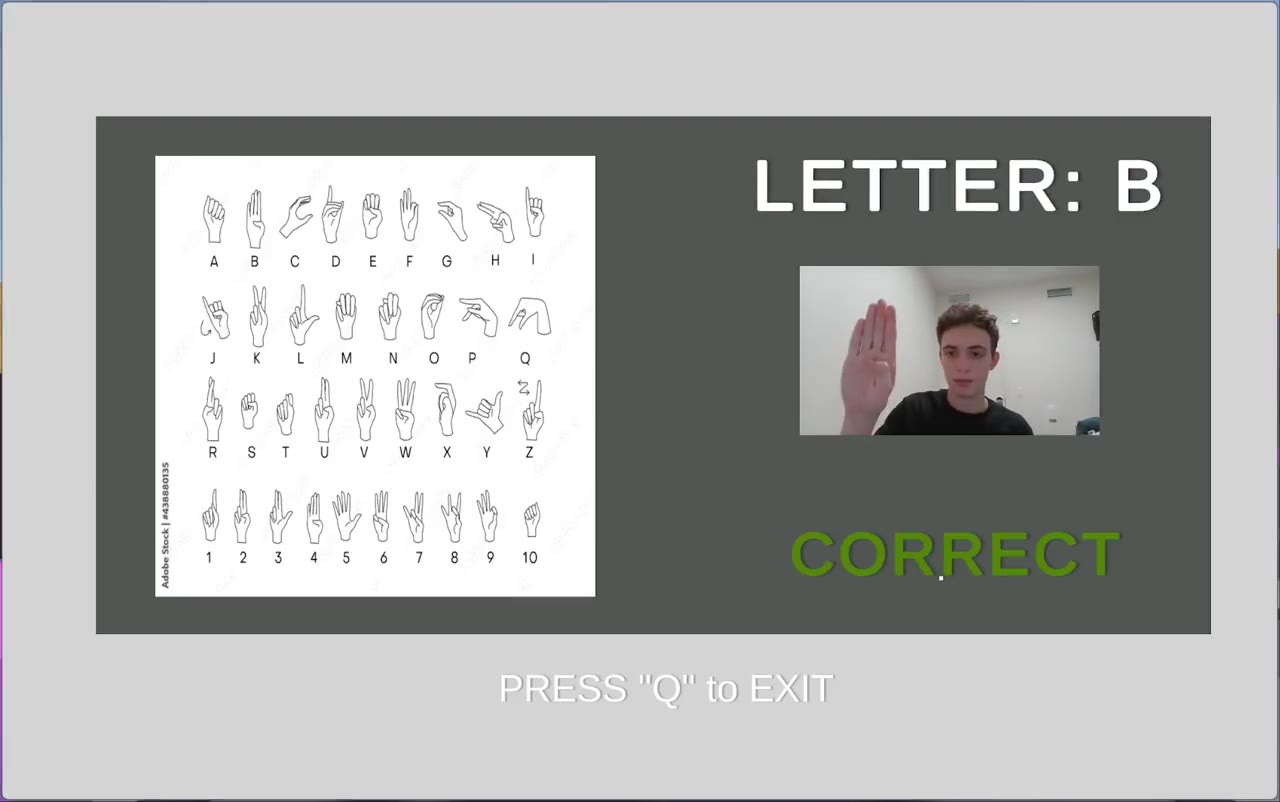
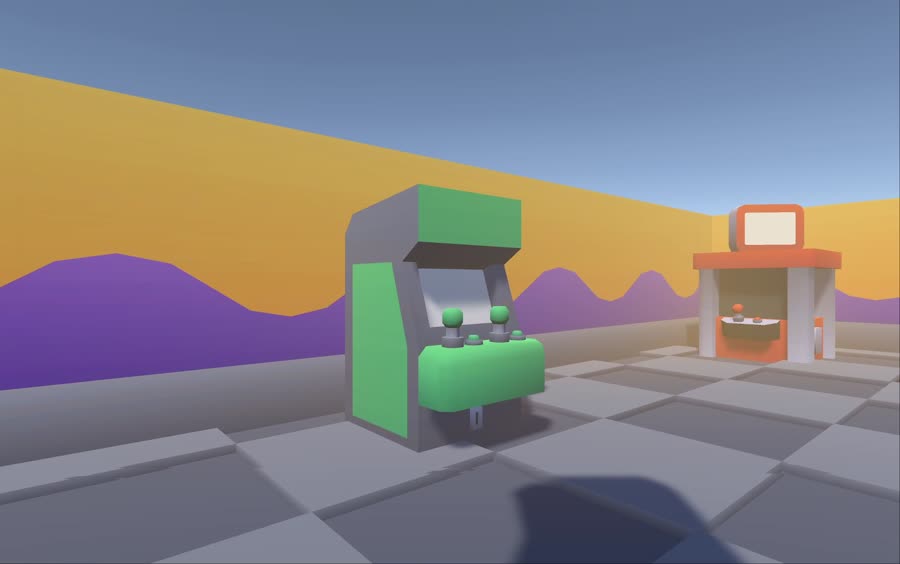
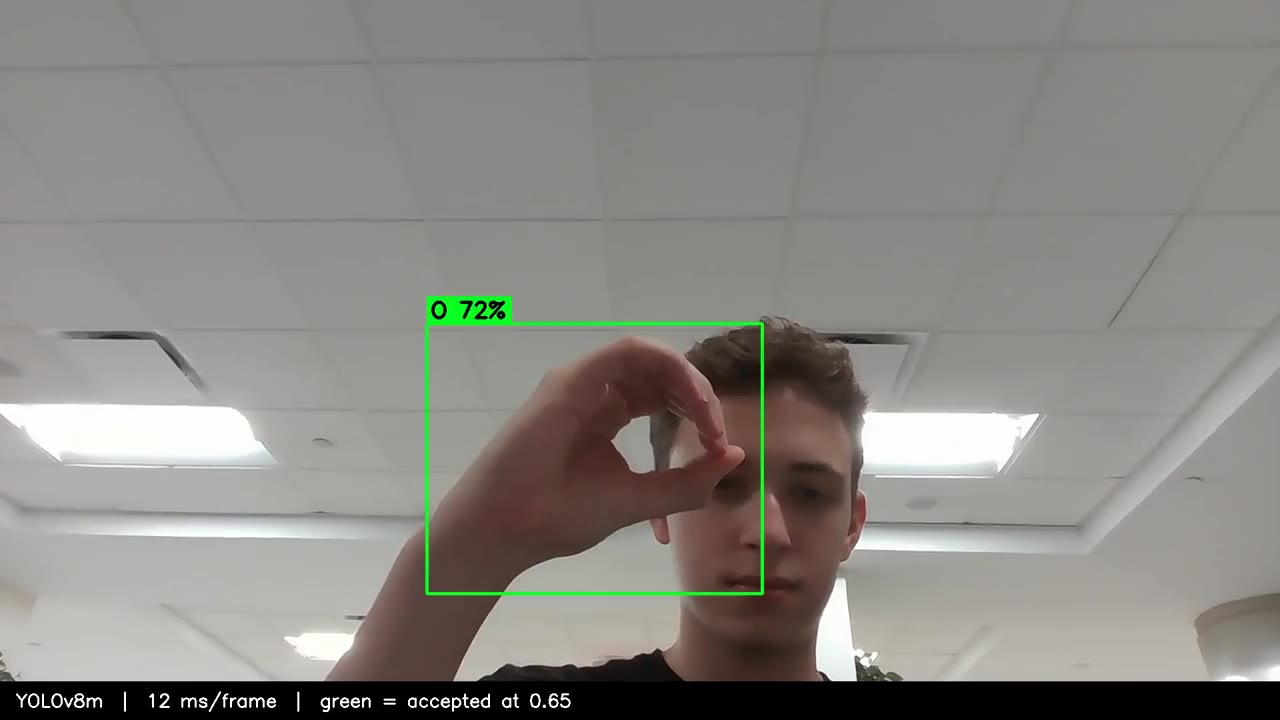
A 3D arcade game that teaches the ASL alphabet: walk up to a cabinet, it asks you to sign a letter, and it watches through your webcam to tell you whether you got it. I trained the detector and built the service behind it, fine-tuning and comparing two YOLOv8 backbones across 26 letter classes, then serving the winner behind an HTTP endpoint that scores a frame in 12 ms on a laptop GPU. The game posts a frame plus the letter it asked for and gets back a verdict, so it never has to know anything about the model. Daniel Estrada built the Unity client.

PythonYOLOv8PyTorchFlaskOpenCVCUDAUnity
The game, recorded at the event. Title screen, the arcade room, then a full round: the cabinet asks for a letter, the webcam feed goes to the service frame by frame, and the verdict comes back.
What the service sees. Green means it accepted the sign at the 0.65 threshold, amber means it saw something but would not commit. The model reaches 0.861 mAP@50-95 on the held-out split and is far less sure on unseen webcam frames, which is a training-data diversity problem and written up honestly here.
Software Team Lead

Panther Robotics Reinforcement learning for robotic-arm control

Aug 2023 - Dec 2024

Led a 7-member team exploring reinforcement learning for robotic-arm control in simulation, comparing policies across physics engines. A research and learning project that got the team fluent in RL and robotics simulation.

KerasPyBulletIsaac SimReinforcement Learning
In the field

Real robots, real environments, real-time perception.

03

Field Demos

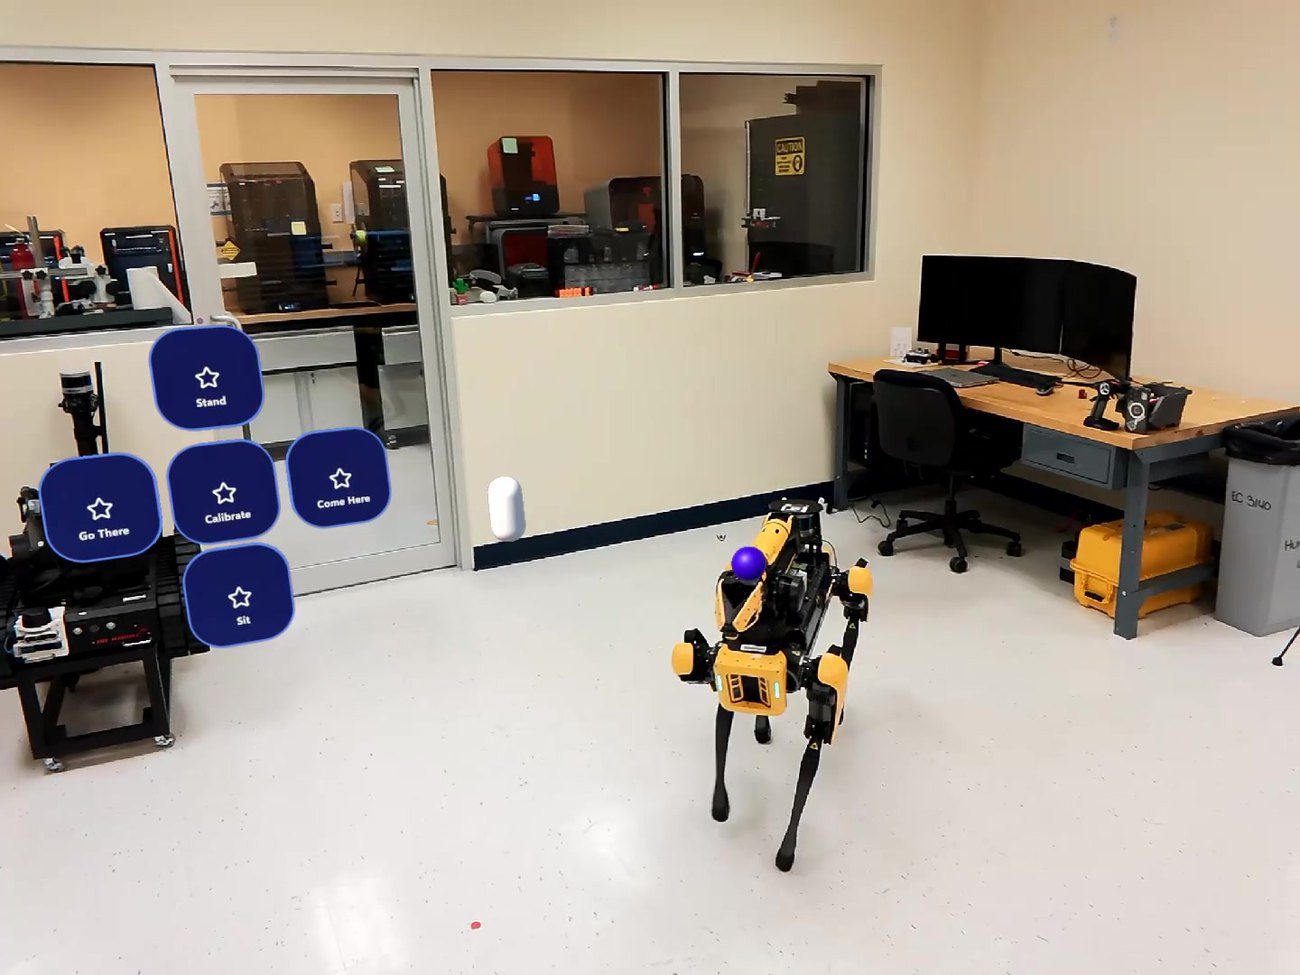
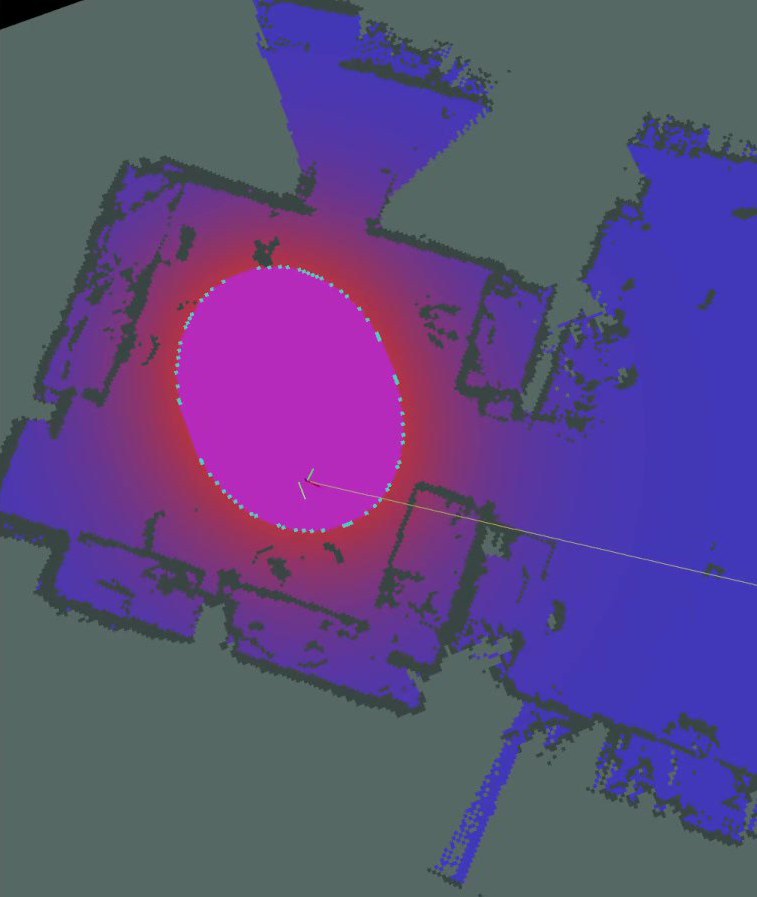
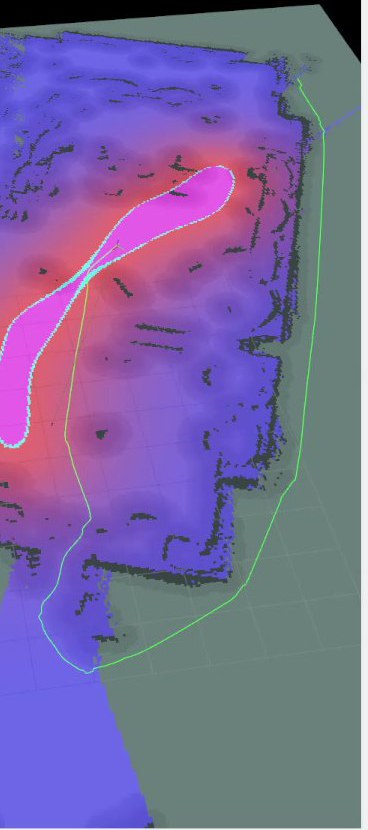
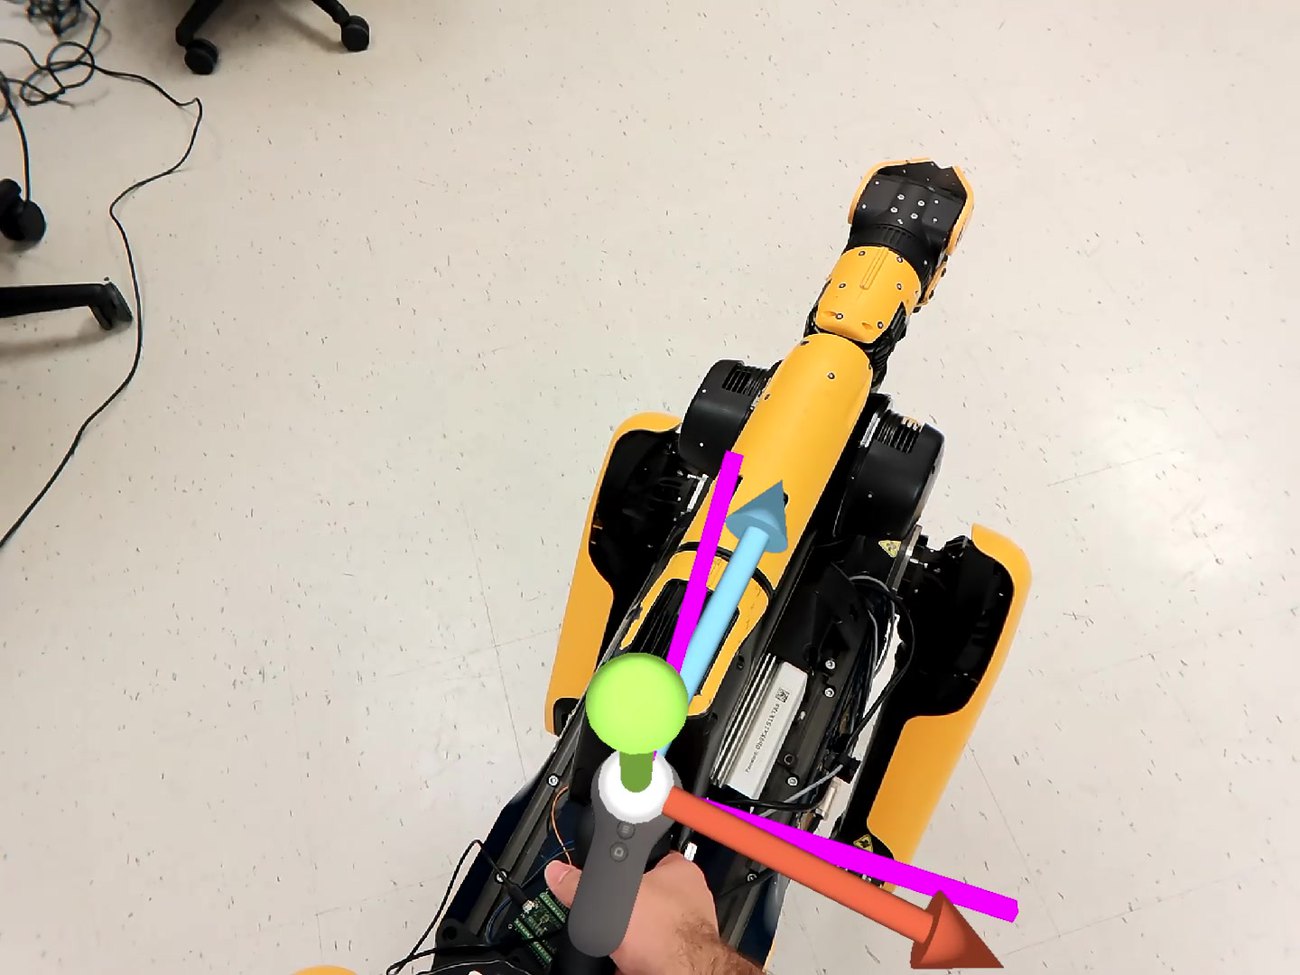
Real-time perception, AR human-robot control, and autonomous exploration on a Boston Dynamics SPOT, captured from live runs in DOE-relevant environments.

Autonomous run. Onboard navigation and SLAM mapping (Nav2) while a GPyTorch Gaussian Process predicts the live CO2 contaminant field in real time, streamed to the operator.
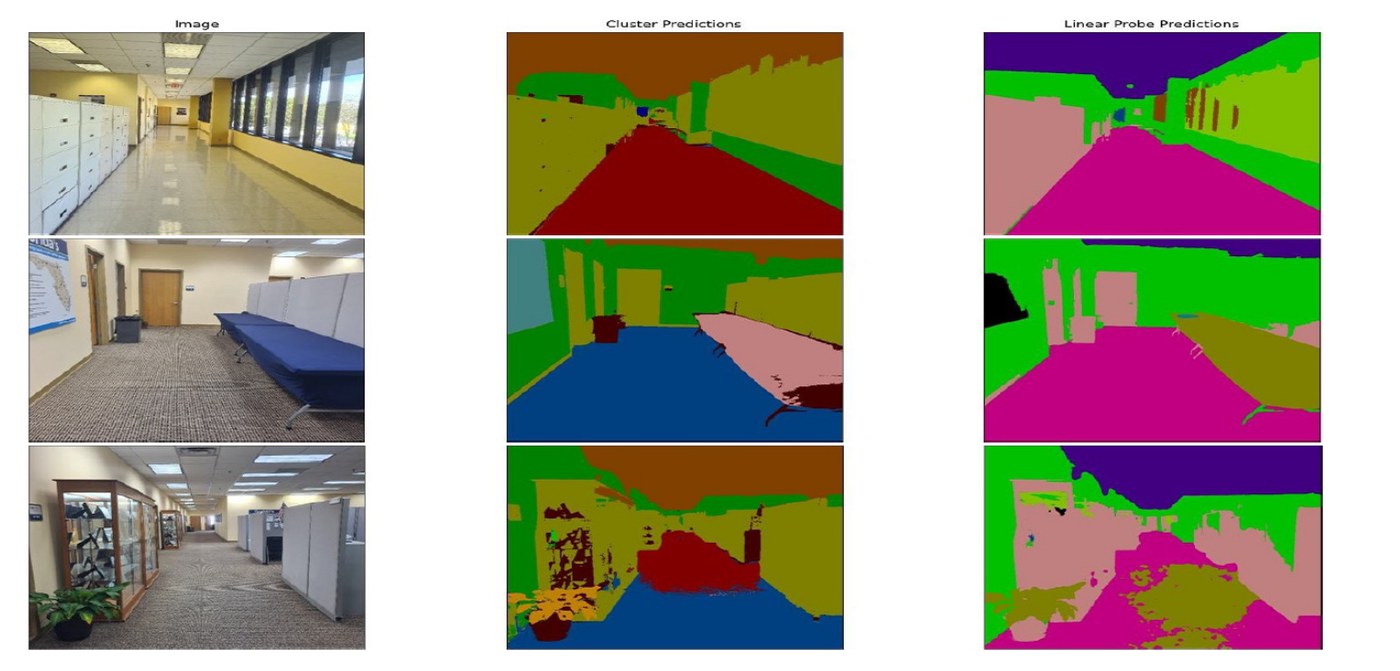
STEGO semantic segmentation showing the input image, cluster predictions, and linear-probe predictions across indoor scenes
Semantic segmentation (STEGO). A self-supervised transformer segments navigation-critical surfaces: input image, cluster predictions, and linear-probe predictions across indoor scenes.
04

Research

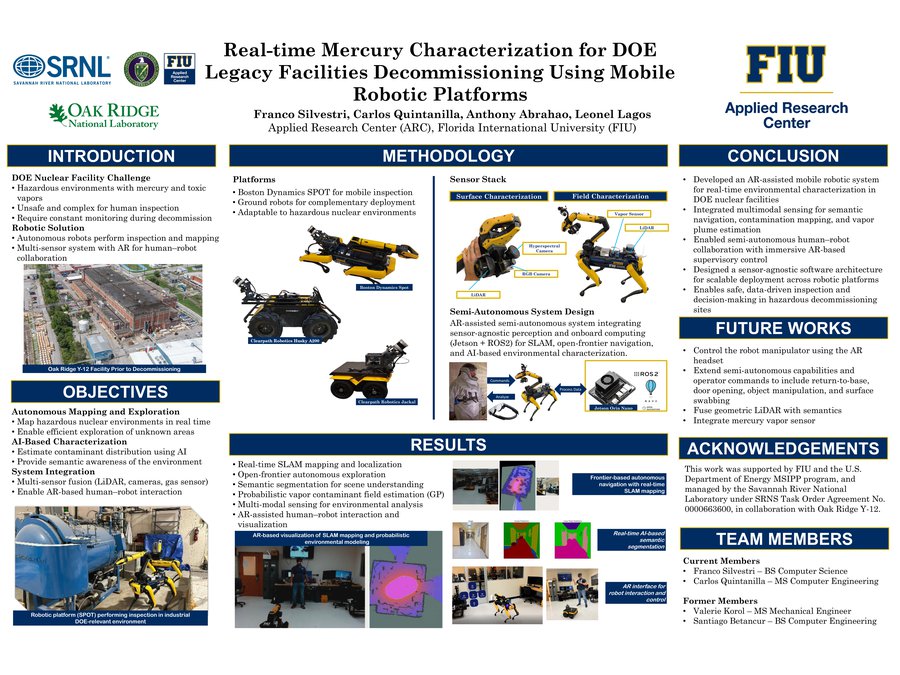
Research poster: Real-time Mercury Characterization for DOE Legacy Facilities Decommissioning Using Mobile Robotic Platforms
First-Author Poster (opens full PDF)

Real-Time Mercury Characterization for DOE Legacy Facilities Decommissioning Using Mobile Robotic Platforms

FIU Undergraduate Research Conference, 2026
Applied Research Center, Florida International University

First author on DOE-funded research (MSIPP, with Savannah River National Laboratory and Oak Ridge Y-12): an AR-assisted mobile robotic system for real-time environmental characterization in hazardous nuclear-decommissioning sites, using multimodal sensing, real-time SLAM & open-frontier exploration, semantic segmentation, and probabilistic vapor-plume estimation via Gaussian Processes on a Boston Dynamics SPOT.

Boston Dynamics SPOTROS 2, JetsonSLAM, Nav2Gaussian ProcessesAR / HRI
Research Collaborators

ARC / FIU Robotics Team

Applied Research Center

Co-authors: Carlos Quintanilla, Anthony Abrahao, Leonel Lagos. Managed by Savannah River National Laboratory (SRNS Task Order 0000663600), in collaboration with Oak Ridge Y-12.

05

INIT FIU

Robotics Technical Lead and E-Board member at INIT, FIU's student developer community (Jan 2025 to present). I run the robotics track: teaching hands-on workshops, mentoring members, and helping organize ShellHacks.

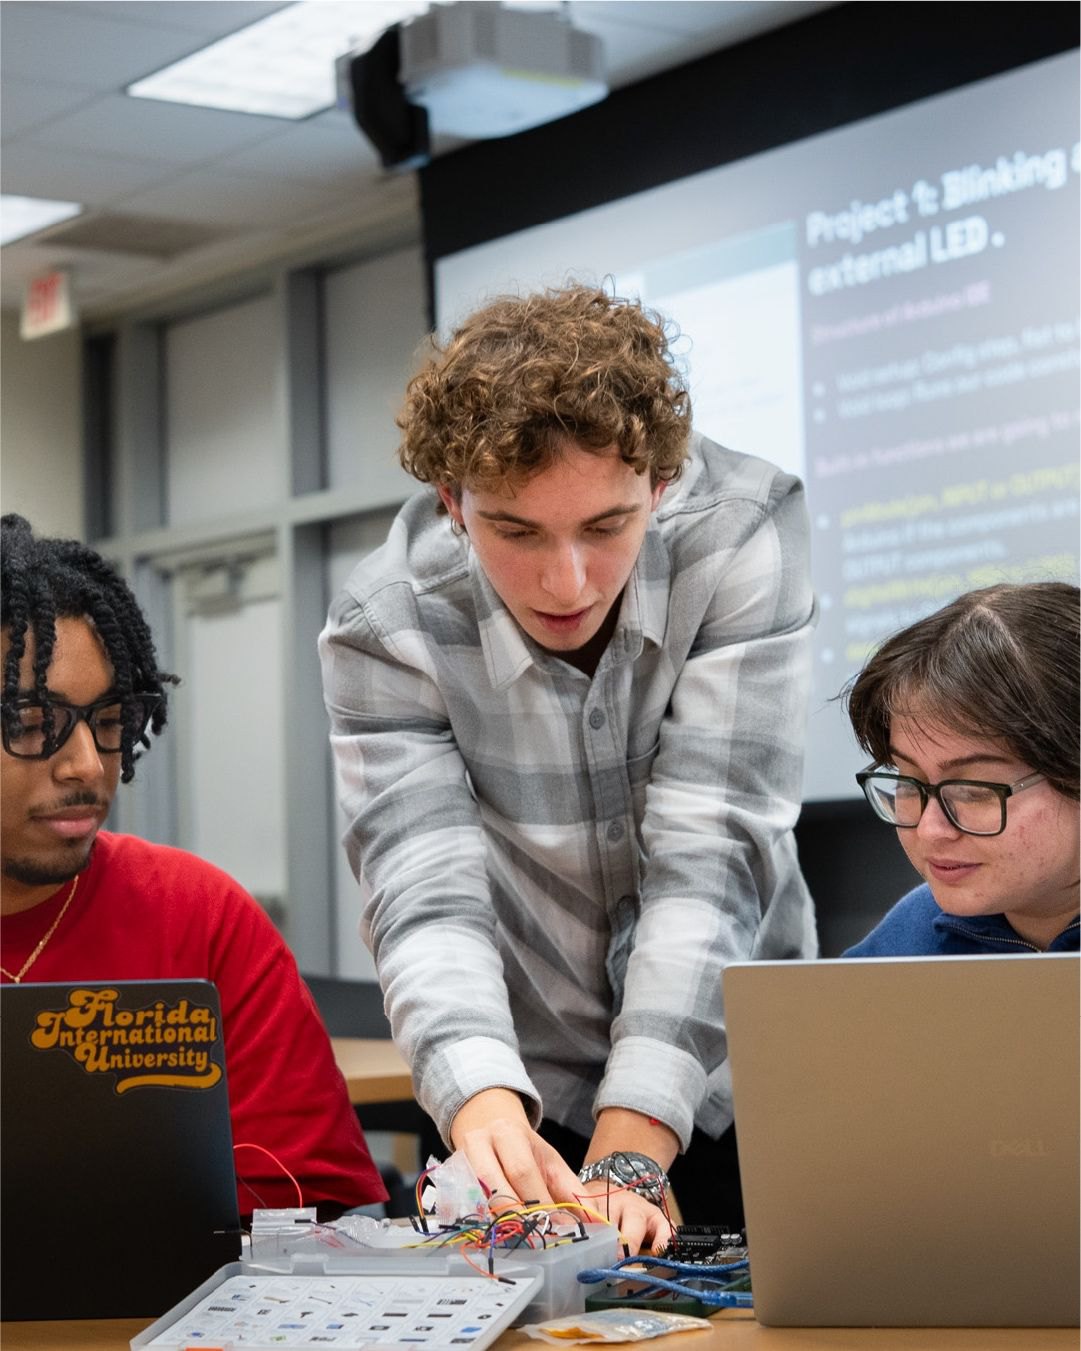
Franco Silvestri teaching a hands-on robotics and electronics workshop at INIT FIU
Teaching a hands-on electronics workshop at INIT
Workshops

16+ hands-on robotics & electronics workshops

I led 16+ embedded systems and robotics workshops, bringing students into electronics and coding, many for the very first time. A couple of the projects we built together:

  • A Harry Potter themed music player driven by an ultrasonic sensor.
  • A Tic-Tac-Toe AI using a minimax algorithm, with wireless control.
ShellHacks, Florida's largest hackathon

Co-organizer

~1,500
Attendees
35+
Sponsors
100
Recruiters
36+
Hours

I also ran a 3 to 5 AM live build with 40+ students: an RGB mood lamp using the Arduino RGB module, remote-controlled with multiple lighting patterns.

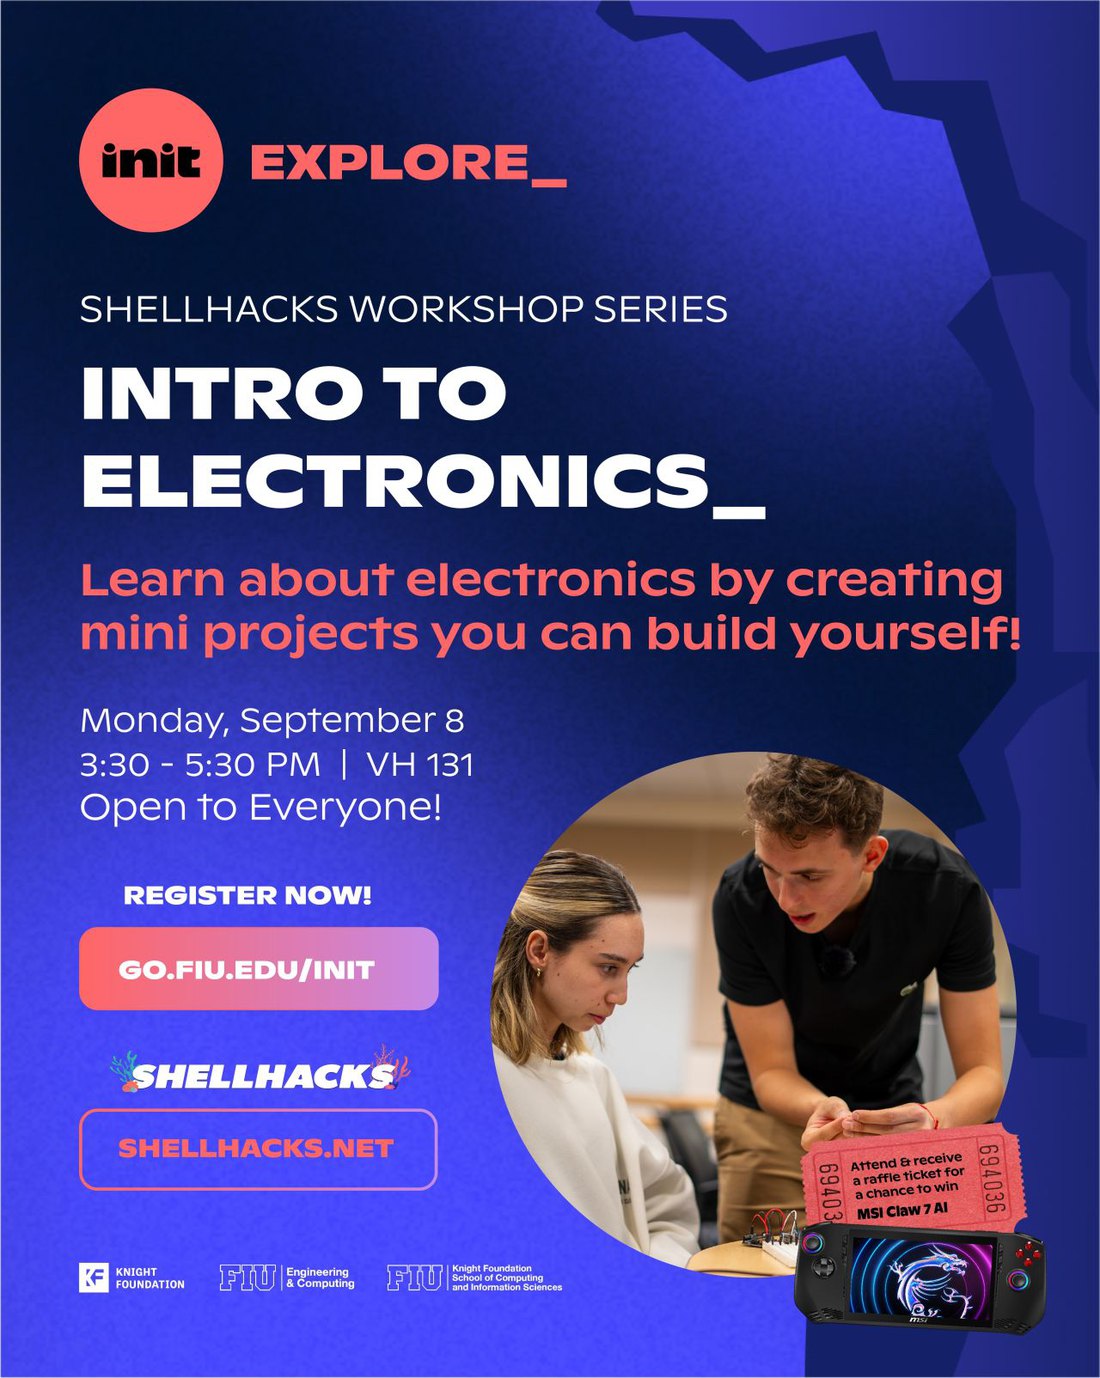
Pre-ShellHacks Intro to Electronics workshop flyer, with Franco helping a student build electronics
Pre-ShellHacks Prep Workshop

Intro to Electronics

Ran a Pre-ShellHacks prep workshop so students would show up equipped with the tools to compete. A quick hands-on primer so first-timers walked in ready to build.

Watch the workshop series
16+ workshops, click to play
or open on YouTube
Featured: final-project workshop
06

The Journey

It started years before college and hasn't slowed down since: self-taught code, first hardware, first real systems.

2020

First lines of code, self-taught

Before college, I taught myself to build. Online university diplomas in Python (225 hours, top marks), Django, and Machine Learning with Python, plus my first freelance work.

2021

First steps in robotics

Joined a hands-on STEM robotics program (Roboteam): my first steps in mechatronics with Arduino. This is where the passion for robots really started.

2023

Computer Science at FIU, Honors College

Started my BS in Computer Science in FIU's Honors College, and led the software team at Panther Robotics, exploring reinforcement learning for robotic-arm control.

2024

Robotics research at the Applied Research Center

Became Perception & Systems Lead on a DOE-funded robotics project, building real-time perception and distributed systems for a Boston Dynamics SPOT.

2025

First internship and leading at INIT

First term in Genworth's IT Development Program, and stepped up as Robotics Technical Lead and E-Board member at INIT, teaching workshops and helping organize ShellHacks.

2026

Platform engineering and first-author research

Returned to Genworth on the Architecture team (platform engineering and DevOps), presented first-author research at the FIU Undergraduate Research Conference, and moved Formira, my pharmacy SaaS, toward its pilot launch.

2027 to 2028

The next chapter

Finishing the accelerated BS, then straight into the MS in Computer Science. Still chasing hard, real-world engineering problems.

07

Toolbox

Languages
PythonC++JavaJavaScript / TypeScriptSQL
Systems & Backend
Distributed SystemsReal-Time SystemsNetworkingROS 2DDS MiddlewareDjango RESTPostgreSQL
Infra & DevOps
DockerKubernetesGitLab CIJenkinsLinuxAWS
ML & Perception
PyTorchGPyTorchCUDATensorRTJetsonSemantic SegmentationSTEGOSLAM, Nav2Sensor FusionGaussian Processes